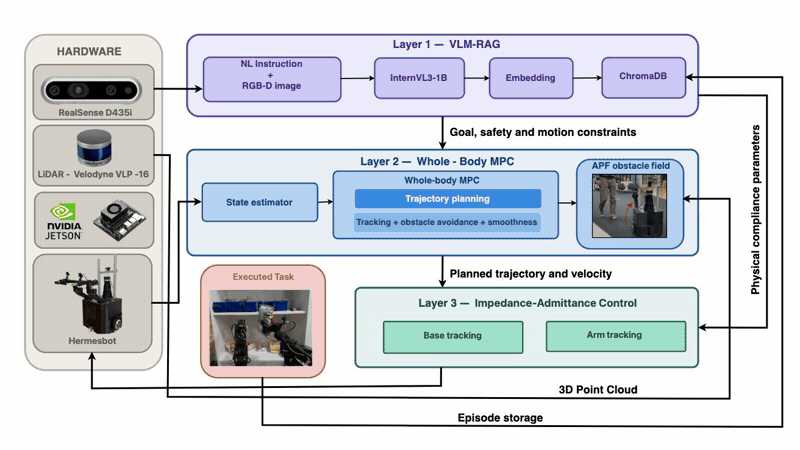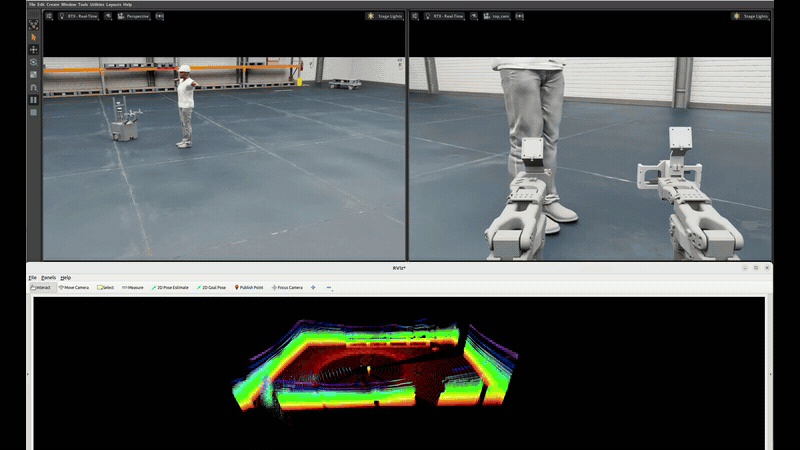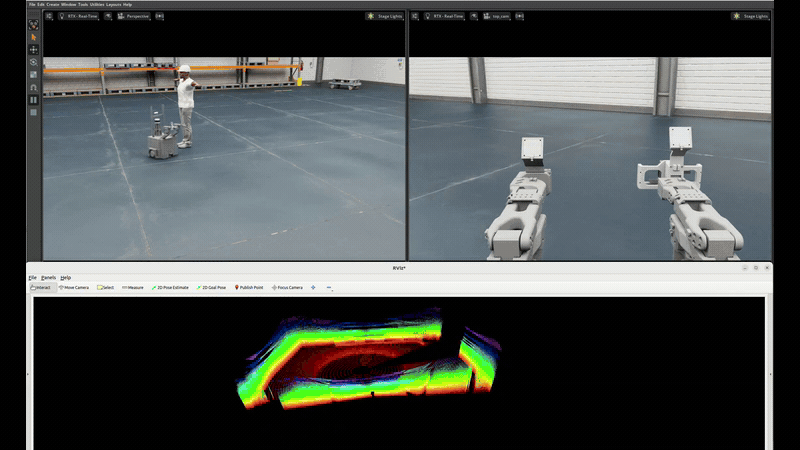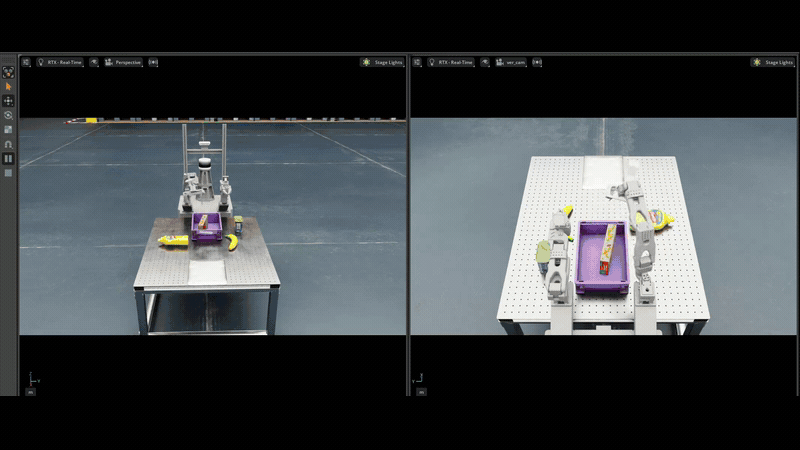
GenerativeMPC
VLM-RAG-guided whole-body MPC with virtual impedance for bimanual mobile manipulation.
MPCVLM-RAGImpedance
Welcome
Robotics software engineer working on Physical AI — bringing robot foundation models and vision-language-action systems from simulation to safe, contact-rich deployment on bimanual and humanoid robots.
My work centers on vision-language-action systems, humanoid and bimanual manipulation, and the compliant control that lets them act safely on real hardware. I build the learning, perception, and control stacks that turn language- and vision-derived intent into safe, contact-rich physical interaction.
VLM-RAG-guided whole-body MPC with virtual impedance for bimanual mobile manipulation.
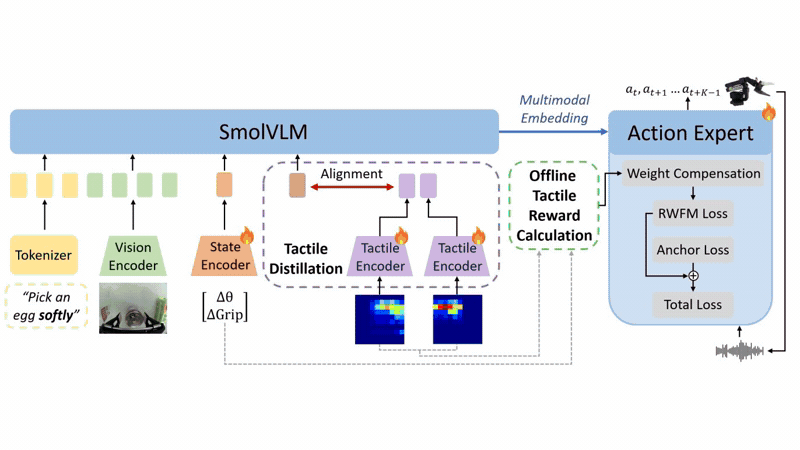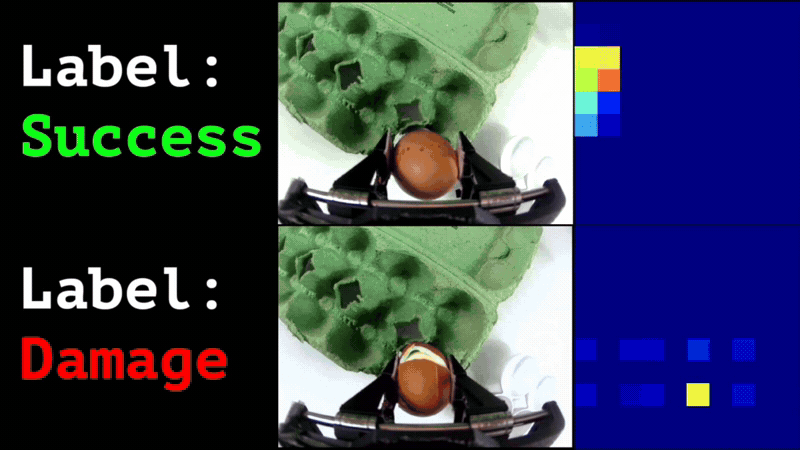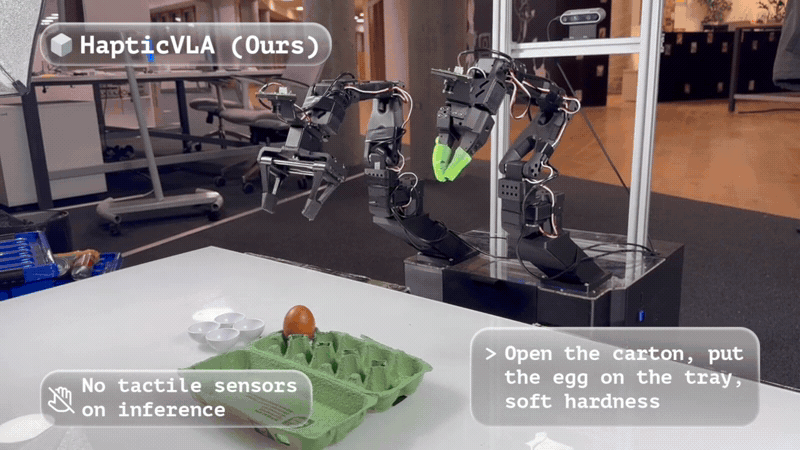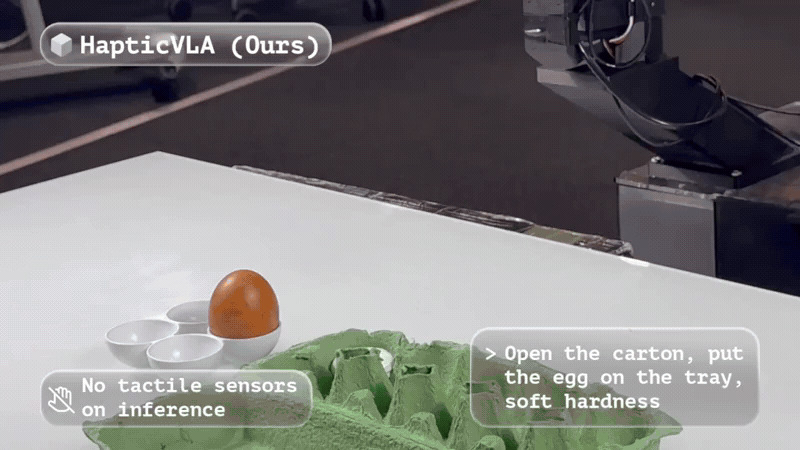
Tactile-aware vision-language-action learning for contact-rich manipulation, no tactile sensing at inference.
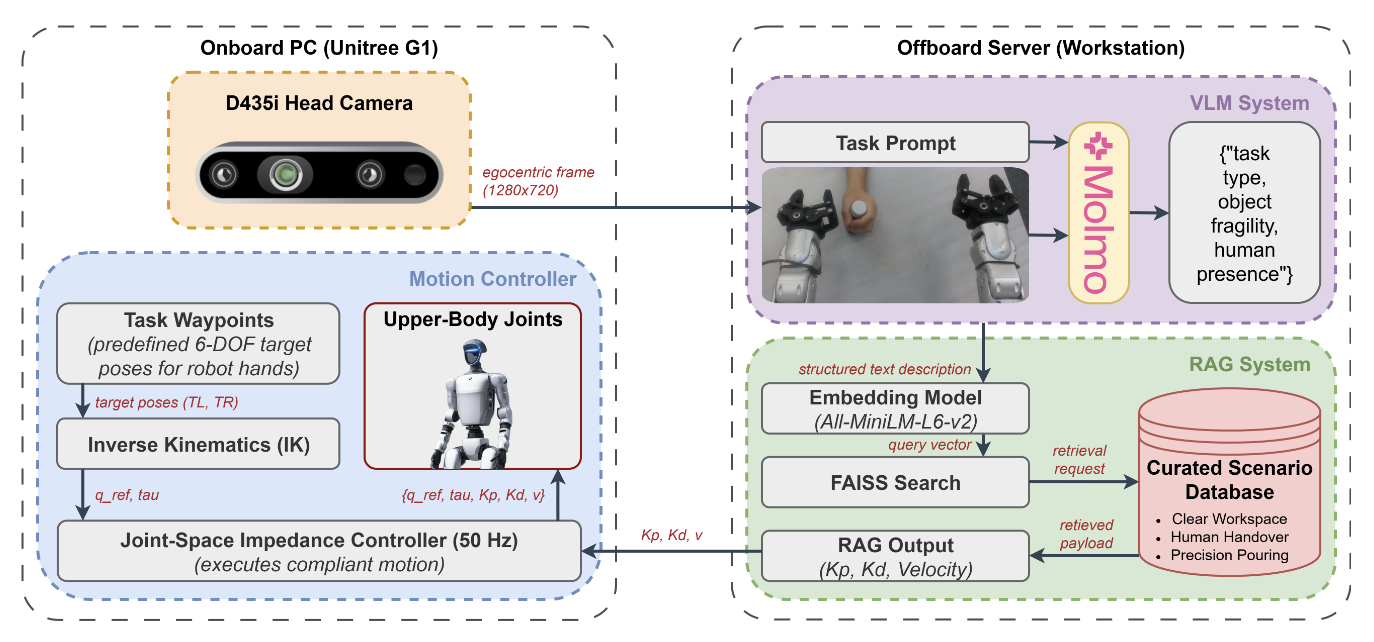
VLM-RAG-driven impedance control for humanoid robots, ensuring safe physical interaction.
Open to collaborations and roles in robotics control, perception, and Physical AI. The fastest way to reach me is email.