Marcelino Fernando/Projects

Projects

Projects

Selected robotics projects spanning Physical AI, vision-language-action learning, bimanual and humanoid manipulation, model predictive control, sim-to-real transfer, and robot foundation models.

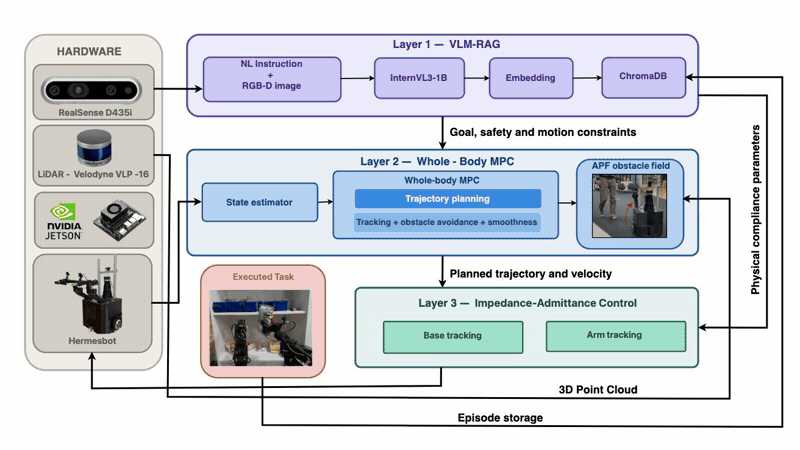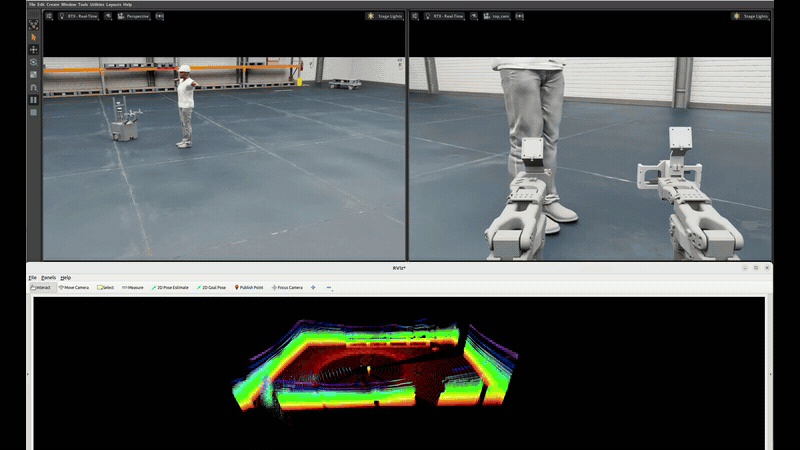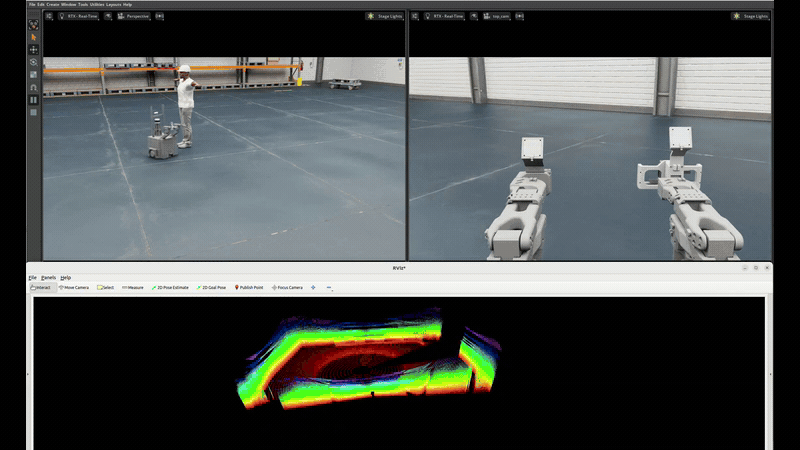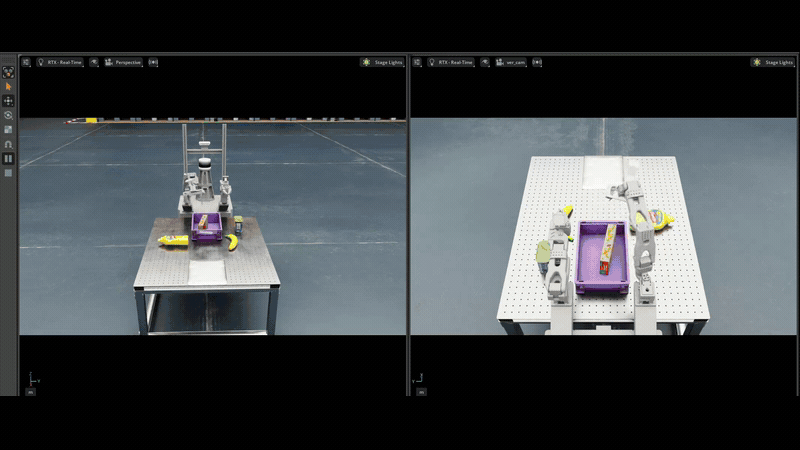
GenerativeMPC — whole-body MPC demonstration

GenerativeMPC

VLM-RAG-guided whole-body MPC framework with virtual impedance for bimanual mobile manipulation. Links semantic reasoning to compliant physical interaction, retrieving task-relevant episodes to configure impedance gains, velocity limits, and safety margins.

Whole-body MPCVLM-RAGVirtual impedance
IEEE SMC 2026 · Accepted · Code planned for releasePaper →
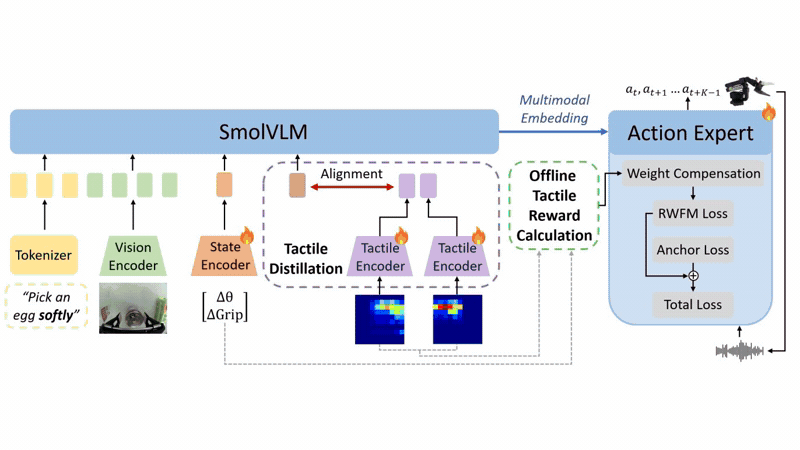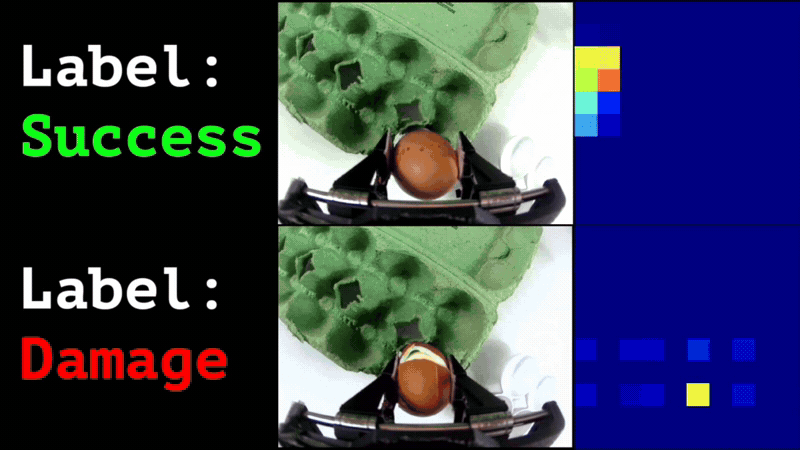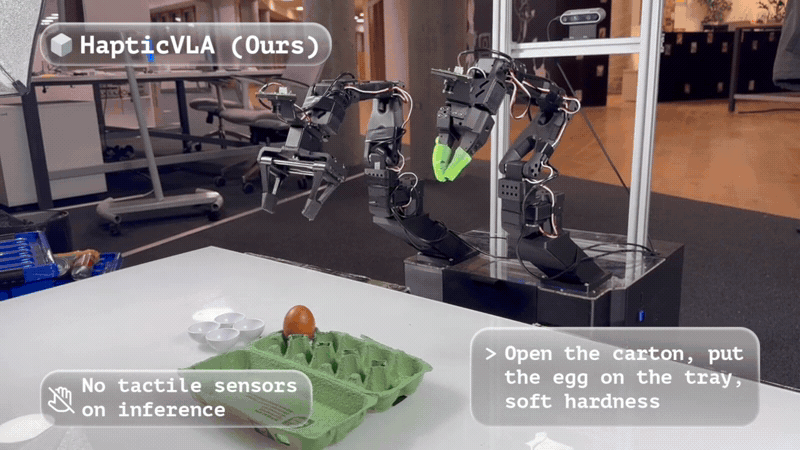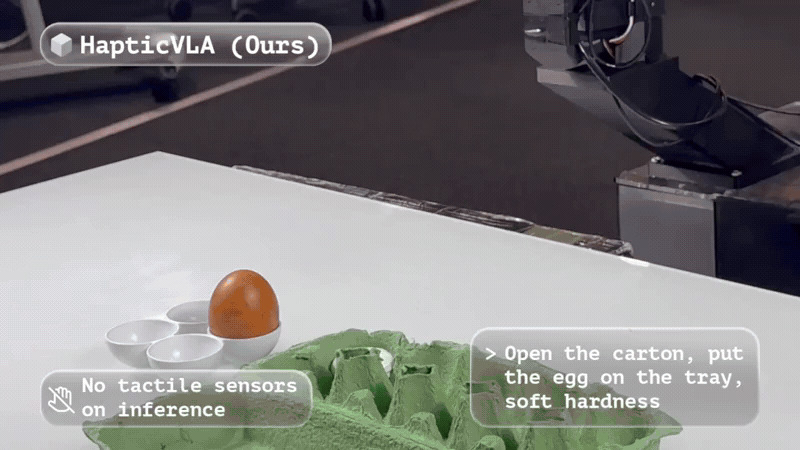
HapticVLA — architecture and contact-rich manipulation demo

HapticVLA

Isaac Sim digital twin and synthetic data-generation pipeline for tactile-aware vision-language-action learning. Enables contact-rich manipulation of fragile and deformable objects without tactile sensing at inference time.

VLAIsaac SimSynthetic data
IEEE/RSJ IROS 2026 · AcceptedPaper →
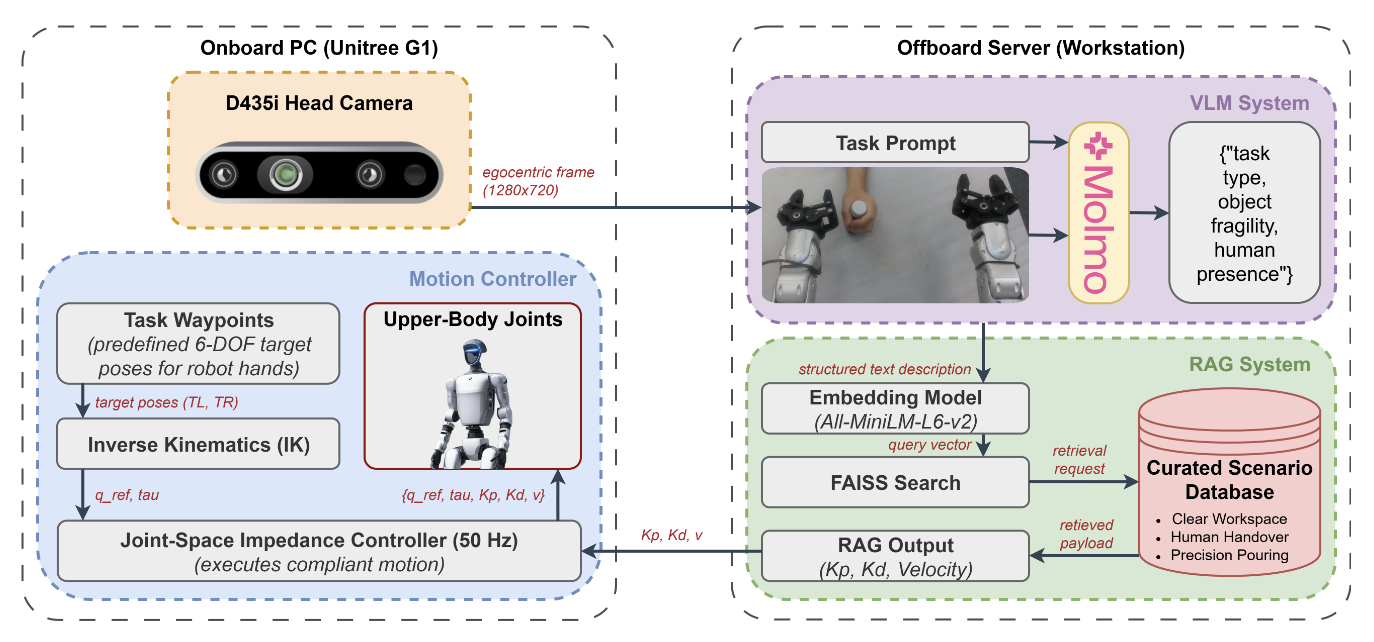
SafeHumanoid — system architecture

SafeHumanoid

VLM-RAG-driven impedance-control system for humanoid robots, connecting retrieved task knowledge to compliant, safe physical interaction. Published at ACM/IEEE HRI 2026.

HumanoidImpedanceVLM-RAG
ACM/IEEE HRI 2026 · PublishedPaper →
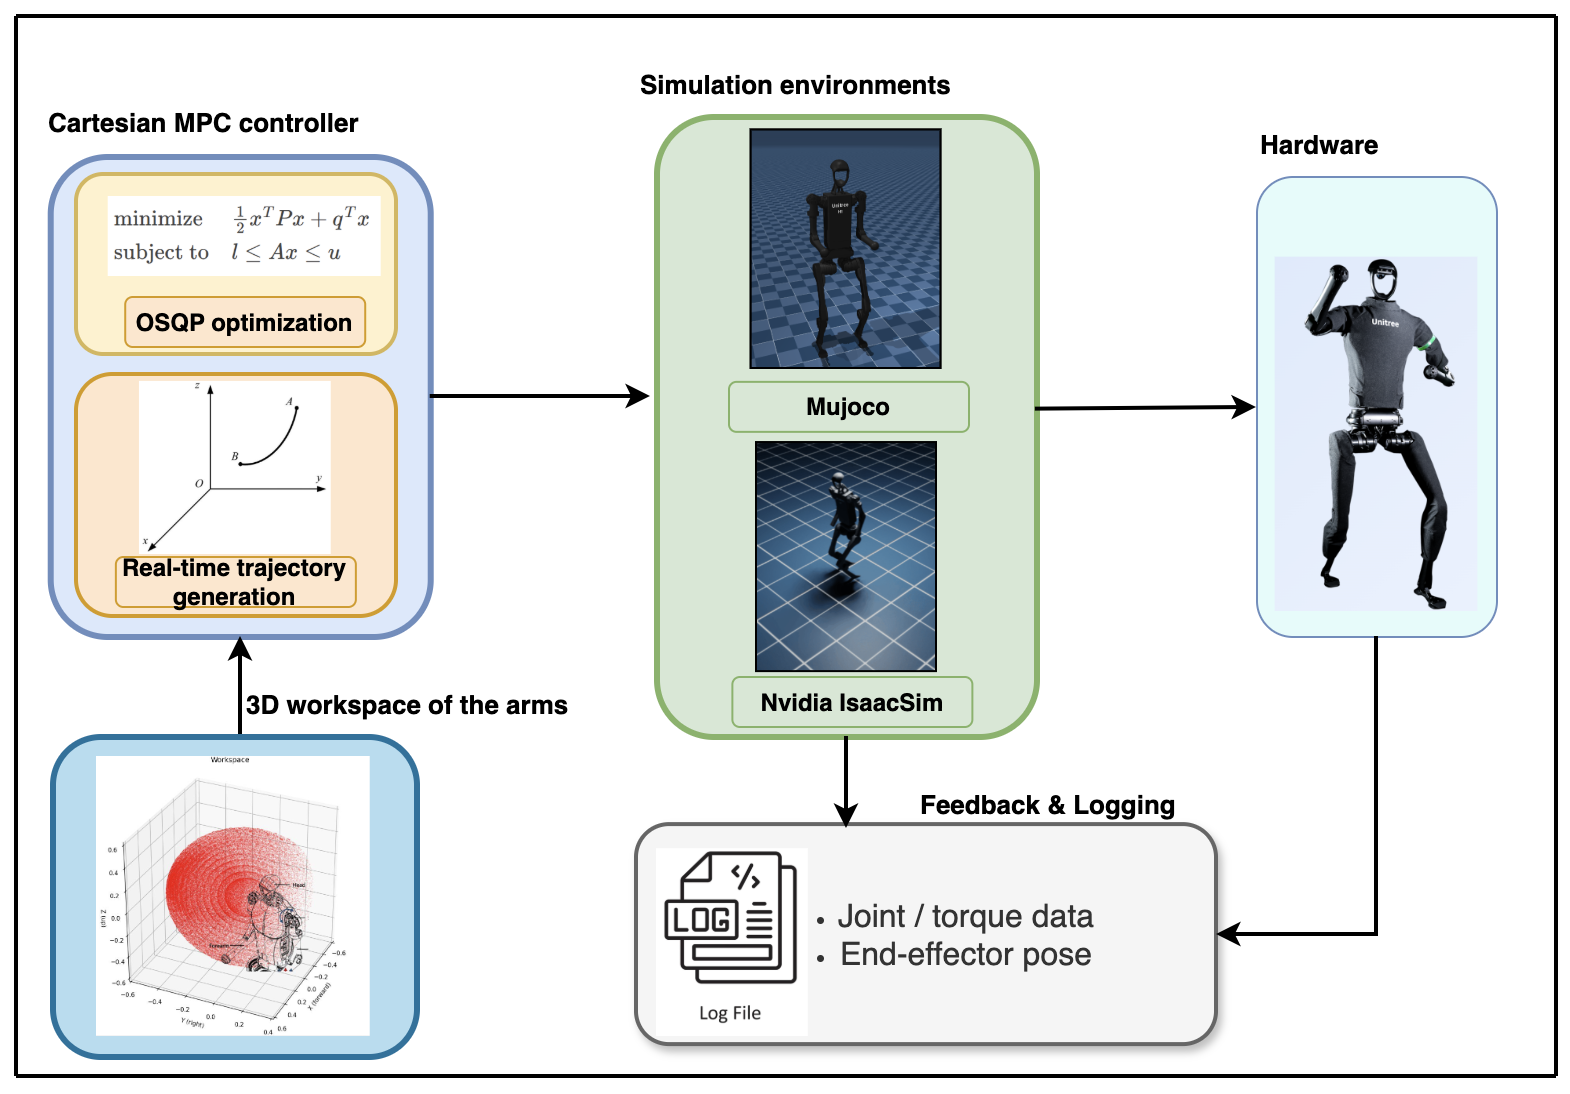
Cartesian MPC for bimanual manipulation — system architecture

Cartesian Model Predictive Control (MPC) for Bimanual Manipulation in Anthropomorphic Robotic Systems

Real-time Cartesian MPC for anthropomorphic bimanual manipulation on the Unitree H1 humanoid, with control latency under 10 ms, hardware-in-the-loop testing, and sim-to-real calibration.

Cartesian MPCBimanualUnitree H1Sim-to-real
MTS AI · 2025Details →
Humanoid dance motion imitation — Unitree H1 demo

Humanoid Dance Motion Imitation via RL

Isaac Lab reinforcement-learning pipeline for Unitree H1 motion imitation, using custom rewards and curriculum learning to reproduce expressive whole-body dance motions.

RLIsaac LabMotion imitation
Unitree H1Code →
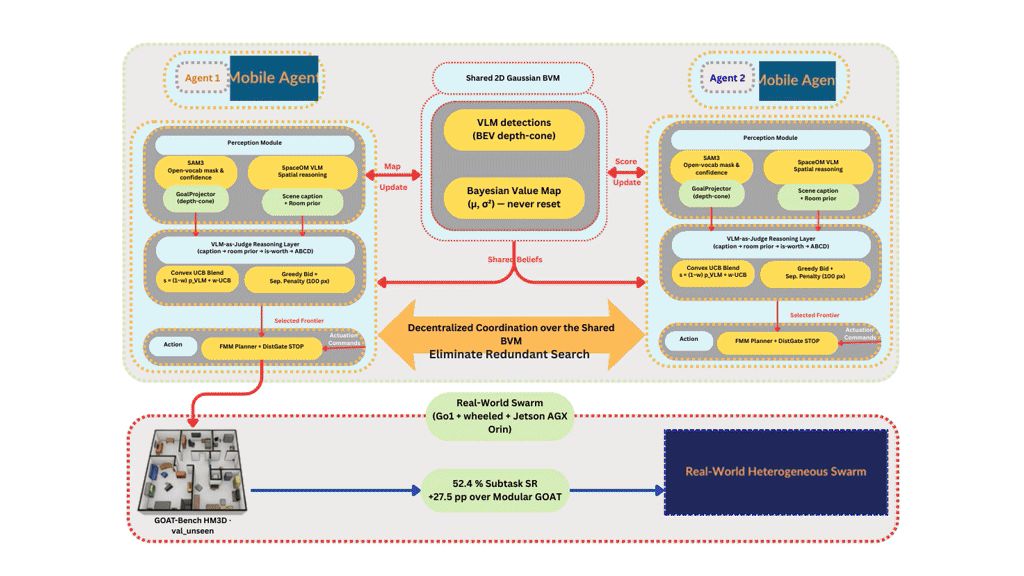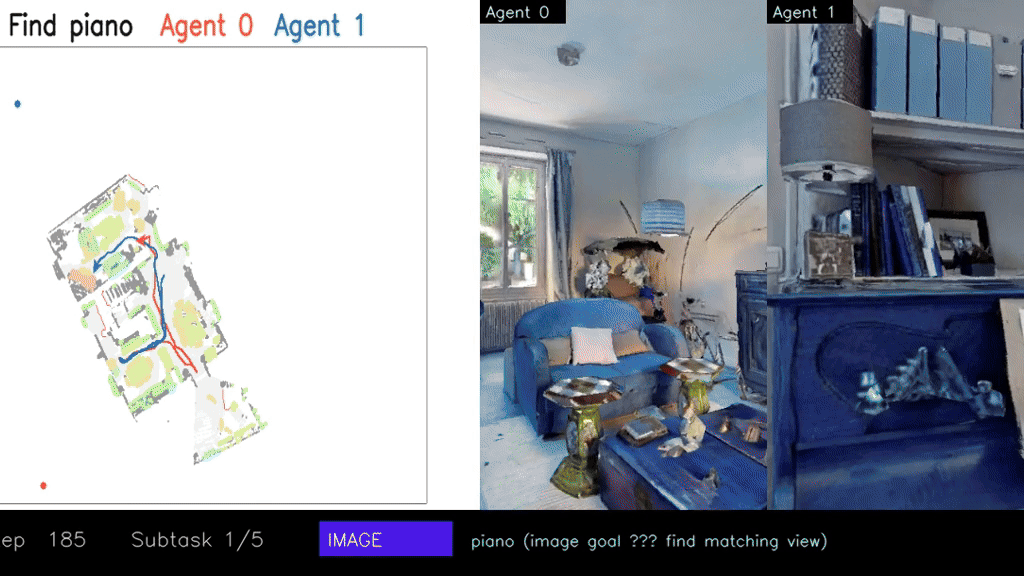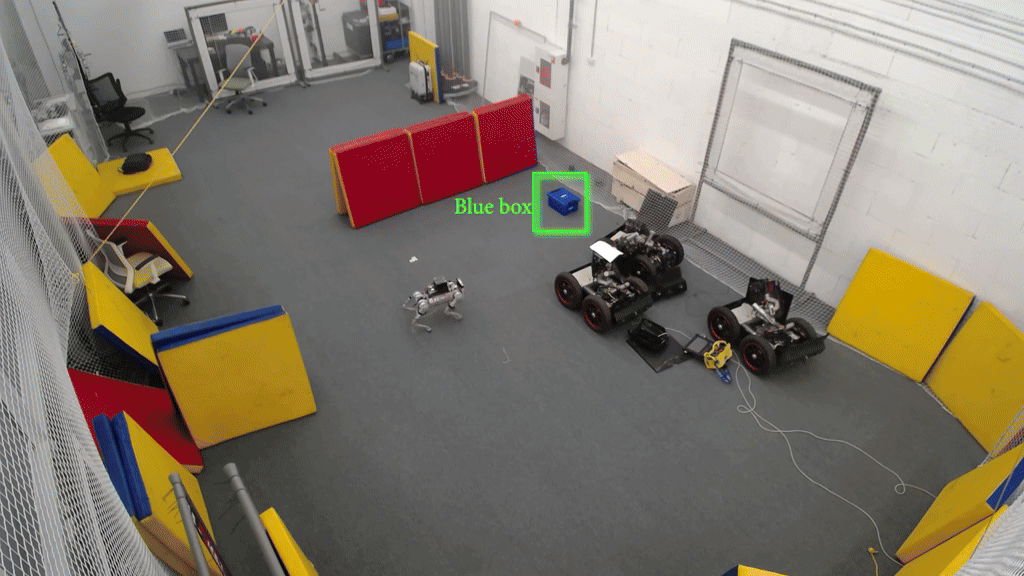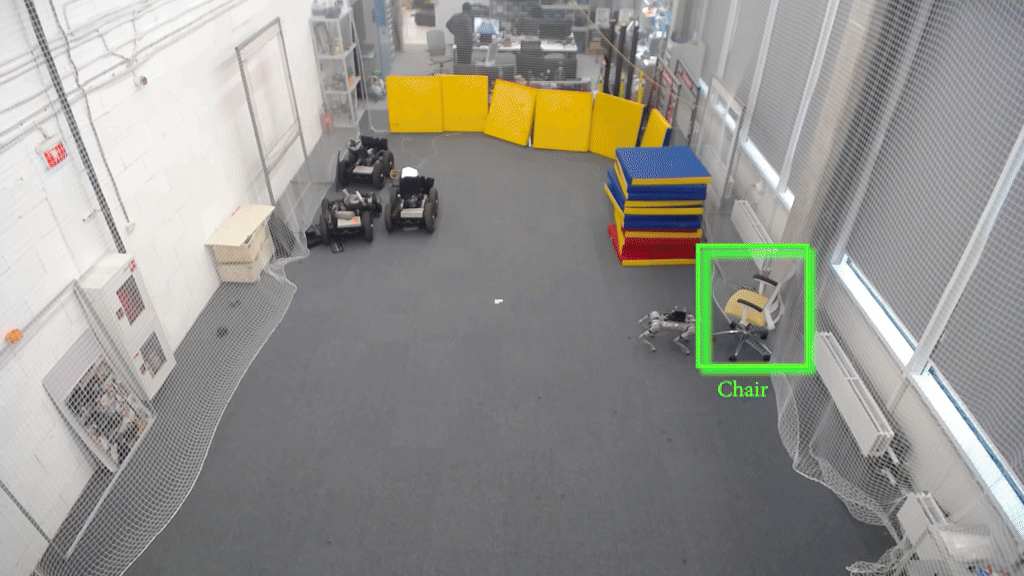
AnyGoal — vision-language guided multi-agent exploration overview

AnyGoal: Vision-Language Guided Multi-Agent Exploration for Training-Free Lifelong Navigation

AnyGoal explores vision-language-guided multi-agent exploration for training-free lifelong navigation, connecting semantic goal understanding with scalable autonomous exploration.

Vision-Language NavigationMulti-Agent ExplorationLifelong NavigationTraining-Free
IEEE CoRL 2026 · SubmittedPaper →