Project
Cartesian Model Predictive Control (MPC) for Bimanual Manipulation in Anthropomorphic Robotic Systems
A Cartesian-space MPC framework for safe, precise, and responsive bimanual manipulation on anthropomorphic robotic platforms — validated in simulation and deployed on real hardware.
Overview
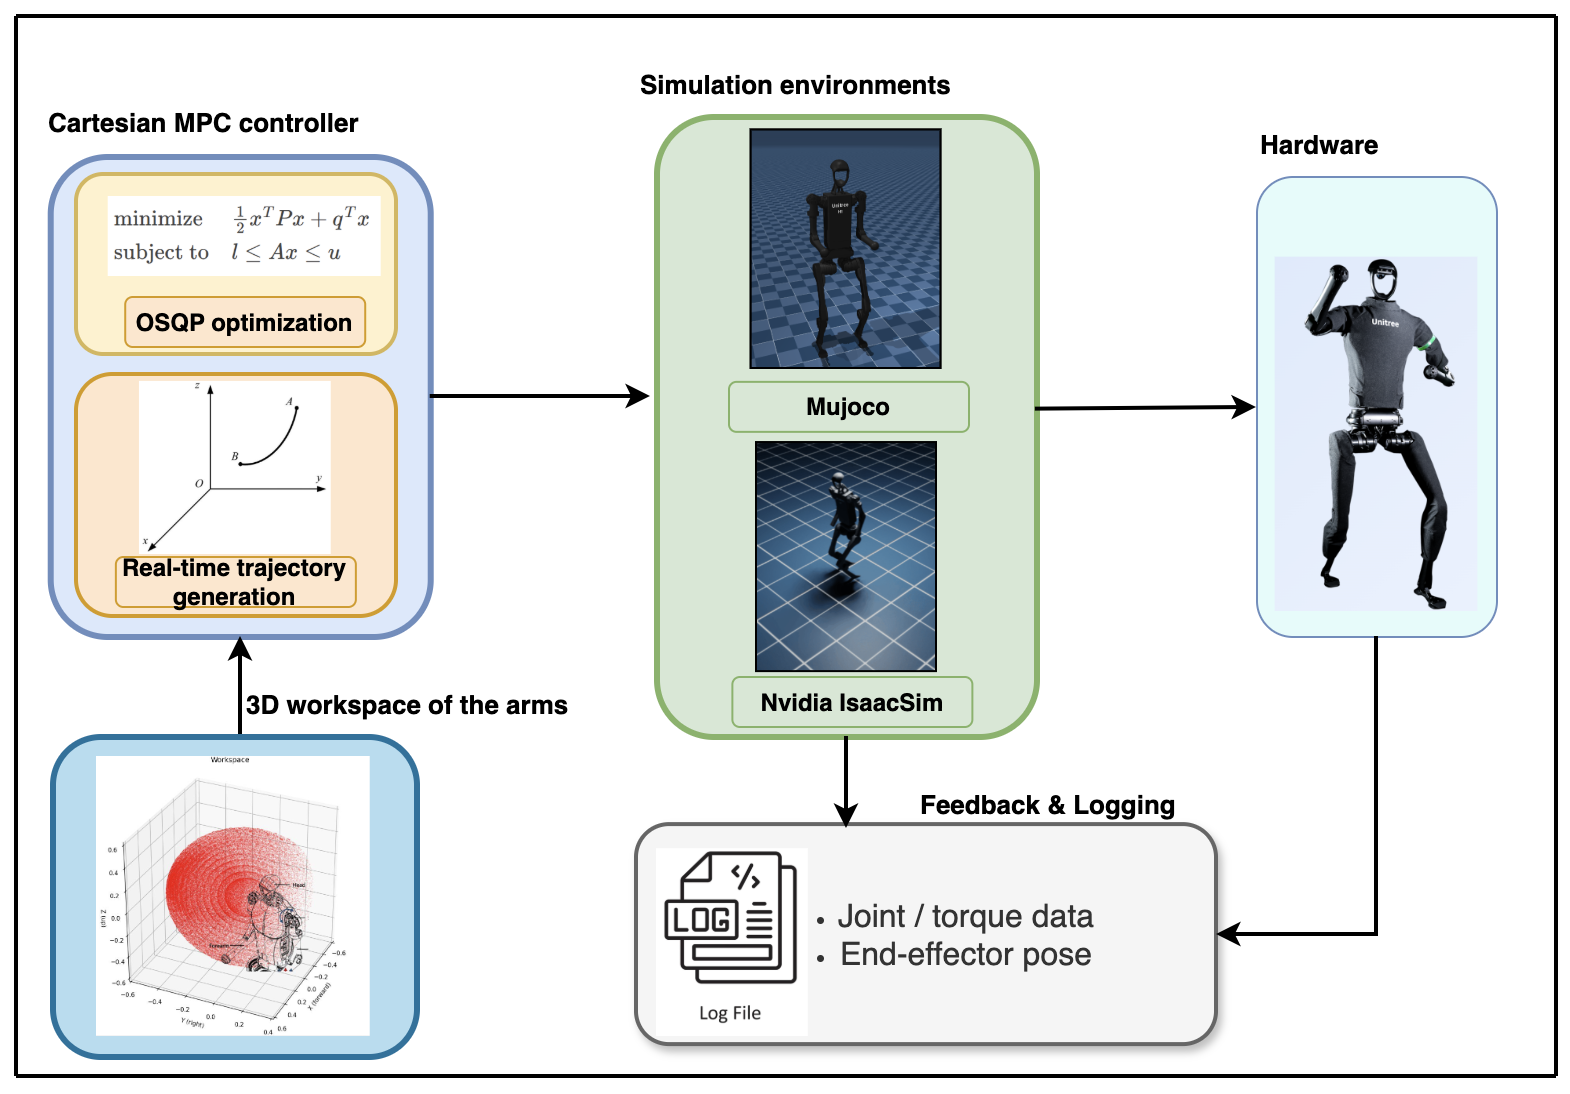
This project presents a Cartesian-space Model Predictive Control (MPC) framework for safe, precise, and responsive bimanual manipulation on anthropomorphic robotic platforms. The controller uses real-time optimization to generate joint trajectories for accurate end-effector position and orientation tracking while respecting safety-related constraints such as torque limits.
The project was validated across simulation and real hardware. The control strategy was tested in MuJoCo and also configured in NVIDIA IsaacSim, demonstrating compatibility across simulation environments. The validated controller was then deployed on the Unitree H1 humanoid robot, bridging simulation performance and practical robotic operation.
Technical Highlights
- Cartesian-space model predictive control for coordinated bimanual manipulation
- Real-time optimization using the OSQP solver
- Accurate end-effector position and orientation tracking
- Constraint-aware control with torque and safety considerations
- Validation in MuJoCo and NVIDIA IsaacSim environments
- Deployment and testing on the Unitree H1 humanoid robot
- Unified simulation-to-real-world control workflow
Results
The controller demonstrated stable trajectory tracking, reduced steady-state errors and overshoot, and safe actuator-effort behavior during bimanual manipulation experiments. The work supports reliable robotic intervention in industrial maintenance scenarios, including data-center maintenance tasks.